Retired
Daedalus
The original flight testbed — retired in favor of Daedalus2, which has less slop in its TVC system and a more mature electrical system.
 Caltech Rocketry
Before the control stack touches a rocket, it flies on drones. The Daedalus testbeds let us crash cheaply, iterate fast, and land often — the platform where our guidance, navigation, and control algorithms rack up flight hours and propulsive touchdowns.
Retired
The original flight testbed — retired in favor of Daedalus2, which has less slop in its TVC system and a more mature electrical system.
Operational
Our self-landing drone controls testbed — the platform where our guidance, navigation, and control algorithms rack up flight hours and propulsive touchdowns.
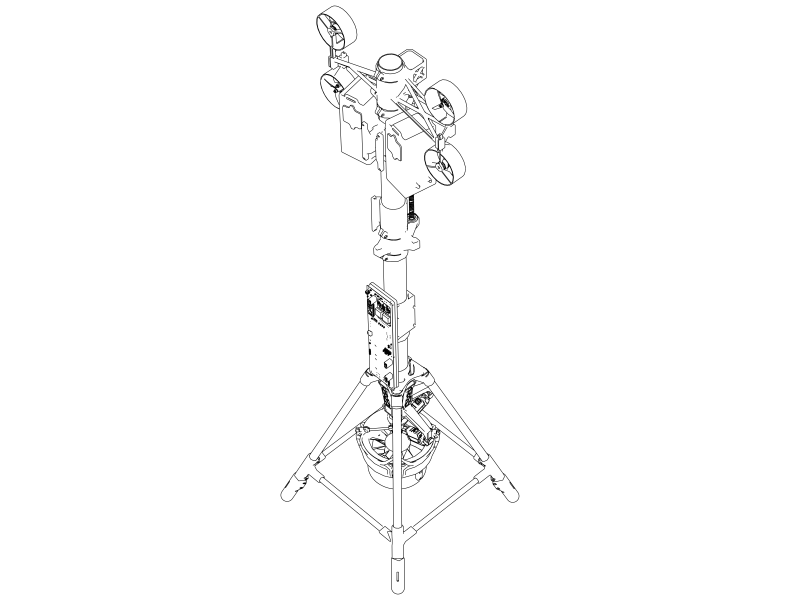
In development
The next-generation testbed, carrying a Jetson Orin Nano — the compute headroom to run heavier state estimation and to flight-test RL‑based control methods.
In development
A testbed built to investigate the belly‑flop maneuver — falling broadside to bleed off speed, then flipping upright for a propulsive landing, the way Starship does it.